One quantitiy to rule them all
1. Effective values
Consider a DC voltage source \(V_X\) attached in parallel with a resistor \(R_{\mathrm{load}}\). The power absorbed by this resistor is then:
Now imagine that this voltage source varies with time and is periodic with period T. It makes no difference what the shape of this waveform is, just that it repeats eventually.

- Definition
-
The effective voltage \(V_{\mathrm{eff}}\) is the value of a constant (DC) source that supplies the same average power to the resistor \(R_{\mathrm{load}}\) as the signal source \(v_X(t)\).
Compute the average power dissipated in the load resistor over a period of an arbitrary waveform \(v_X(t)\).
A DC source of the correct value, the effective voltage will supply the same power to this resistor.
Throw in a square-root and out pops our definition of root-mean-square:[1]

-
An RMS quantity is a scalar value --- not a function of time.
-
RMS is synonomous with effective value.
-
RMS has to do with power at the core of its definition.
2. Composite waveforms
Superposition is a powerful property of linear systems because it allows decomposing a signal into a sum of several signals (usually sinusoids but not necessary), which can then be treated separately.
-
How does superposition work for RMS quantities?
Be careful, it may not be what you would guess! Power quantities behave differently than voltage and current quantities.
Consider a signal composed of two periodic waveforms v1 and v2 with periods T1 and T2. Again, it doesn’t matter the shapes as long as each part is periodic, which is the whole point of the effective value idea. Since both are periodic, then the composite signal is also periodic with period T = T1 T2. Note that T can be any common multiple of the individual periods.
Compute the (square of the) RMS of this signal by using the definition
Since integration is a linear operator, expand into three parts to better inspect each term
We see familiar expressions in the first and third terms --- they are simply the RMS values of the two component signals, \((v_{1\,\mathrm{RMS}})^2\) and \((v_{2\,\mathrm{RMS}})^2\). The second term requires the careful treatment.
-
If signals \(v_1\) and \(v_2\) are orthogonal over the interval \([0,T]\) then this term is zero (the very definition of orthogonal). It turns out that any two sinusoids of different frequencies, integrated over their the least common multiple of their respective periods, are orthogonal.
-
Another way to say this is this second term goes to zero if \(v_1\) and \(v_2\) are uncorrelated.
Therefore, for the sum of uncorrelated signals, the composite’s RMS value is
This is called the root sum (of the) squares or RSS for short.
|
To repeat: RSS, root sum of the squares, only works when the signals are (choose one, choose all):
|
3. RMS of common wave shapes
Few people relish the thought of computing an integral just to get an “effective value,” but that’s the definition.
Fortunately, there are a few common wave shapes that that we encounter all the time.
3.1. sinusoid
Signal: \(v_X(t) = A \sin(2\pi f t)\)
-
Repeat this calculation if the signal is: \(v_X(t) = A \cos(2\pi f t)\) ?
-
If you have a 120 VRMS signal (say, from a power outlet), what is the peak voltage value?
3.2. triangle
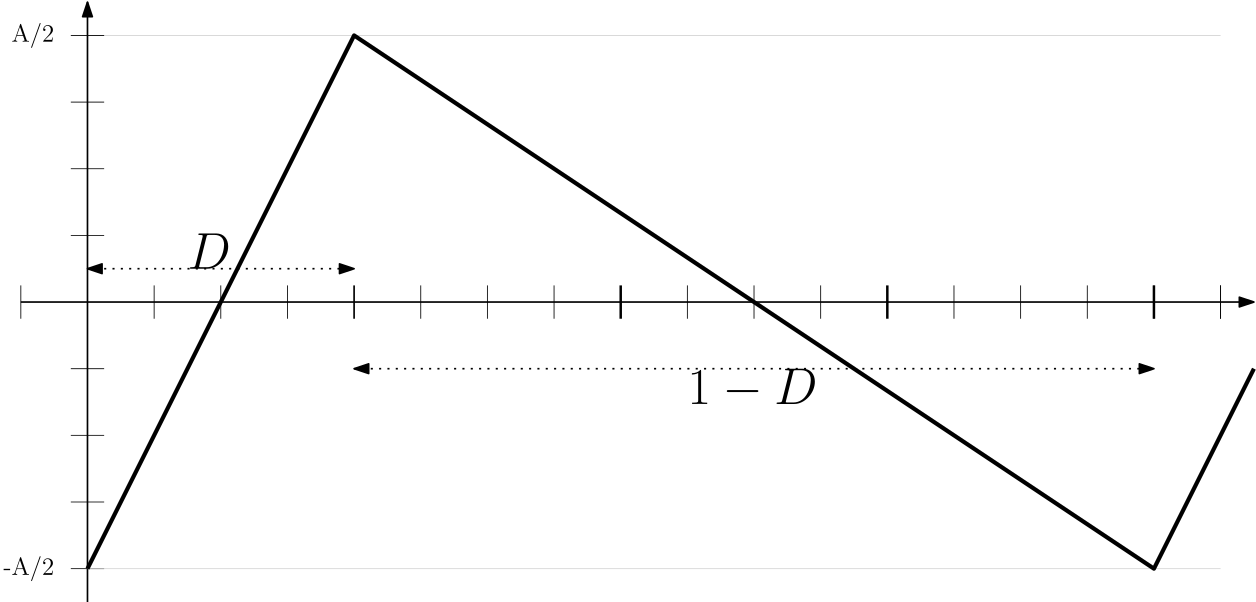
This is a fun one! Set up a triangle wave that is centered around zero, meaning that the average value must be zero. It is useful to specify the “duty cycle” as the proportion of time the waveform spends linearly rising compared to the period (the other portion the signal is linearly falling). Then you only complete this integral once and get a parameterized result.
You need to do this by hand at least once in your life before you memorize the result. It is useful for switching circuits with integrator-like devices (inductor current with a switched voltage, capacitor voltage with a switched current) that show up in e.g. power electronics.
3.3. square
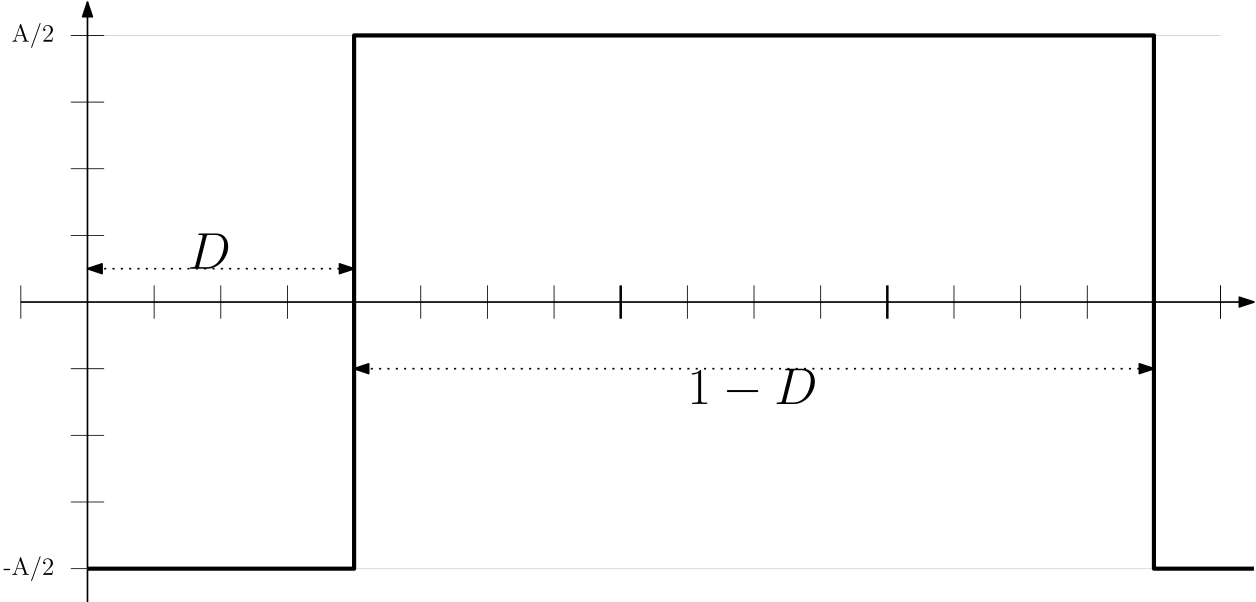
Two fun ones, the first is easy.
-
50% duty cycle, centered around 0 with peaks at ±A.
-
D% duty cycle, with peaks at ±A. (use D as 0..1)
3.4. Three sinusoids
A superposition harmonic sinusoids. Be sure to start with the definition of RMS and take care of your algebra. Average over the least common multiple of the three periods.
4. Other usage domain examples
| Domain | Quantity | Description |
|---|---|---|
Electrical power |
RMS line voltage/current |
Used to specify AC power systems, equipment ratings, conductor heating, and insulation requirements. Nominal values such as 120 V AC refer to RMS voltage rather than peak voltage. |
Electronics |
RMS noise voltage |
Characterizes random electrical noise whose instantaneous mean may be nearly zero. RMS noise gives a useful measure of noise amplitude and is directly related to noise power. |
RF engineering |
RMS RF voltage/current |
Used to relate modulated or irregular RF waveforms to average delivered power, particularly when the waveform cannot be described adequately by a single peak amplitude. |
Signal processing |
RMS signal amplitude |
Gives a scalar measure of the magnitude or energy content of a sampled waveform: \(x_\mathrm{RMS}=\sqrt{\frac{1}{N}\sum_{n=1}^{N}x_n^2}\). |
Audio engineering |
RMS audio amplitude |
Describes the effective amplitude of an audio waveform and is generally more representative of sustained signal level than instantaneous peak amplitude. |
Acoustics |
RMS particle velocity |
Describes the oscillatory velocity of air particles in a sound field. It is used with sound pressure to calculate acoustic intensity and acoustic impedance. |
Mechanical engineering |
RMS vibration displacement |
Measures the typical magnitude of an oscillating displacement about an equilibrium position without positive and negative excursions canceling. |
Mechanical engineering |
RMS vibration velocity |
Widely used in rotating-machinery condition monitoring because vibration velocity RMS correlates well with overall machine vibration severity. |
Mechanical engineering |
RMS vibration acceleration |
Common accelerometer-based measure of vibration strength, particularly for high-frequency vibration, impacts, bearing faults, and machinery diagnostics. |
Structural engineering |
RMS structural displacement |
Describes typical motion of buildings, bridges, towers, or other structures under wind, traffic, machinery, or other time-varying excitation. |
Structural engineering |
RMS structural acceleration |
Used to quantify vibration experienced by structures and occupants, including human-comfort assessment in tall buildings and floors. |
Vehicle engineering |
RMS acceleration |
Used to characterize vehicle vibration, ride quality, and occupant exposure to whole-body vibration over time. |
Aerospace engineering |
RMS vibration acceleration |
Used in spacecraft, launch-vehicle, and aircraft vibration testing to characterize random vibration environments and qualification test levels. |
Aerospace engineering |
RMS pointing error |
Measures the typical angular deviation of a spacecraft, telescope, antenna, or guidance system from its desired pointing direction. |
Control systems |
RMS tracking error |
Measures the typical difference between a commanded trajectory and the actual system response over an interval. |
Robotics |
RMS position error |
Summarizes robot position or trajectory accuracy by calculating the RMS difference between commanded and measured positions. |
Physics — kinetic theory |
RMS molecular speed |
Characteristic speed of molecules in a gas, \(v_\mathrm{RMS}=\sqrt{\left\langle v^2\right\rangle}\). For an ideal gas, \(v_\mathrm{RMS}=\sqrt{\frac{3kT}{m}}\), directly connecting RMS speed to molecular kinetic energy. |
Statistical mechanics |
RMS velocity |
Used for particles whose vector-average velocity may be zero even though their kinetic energy is nonzero, since kinetic energy depends on \(v^2\). |
Condensed-matter physics |
RMS atomic displacement |
Describes thermal vibration of atoms around their equilibrium lattice positions and is related to temperature and crystal vibration behavior. |
Plasma physics |
RMS particle velocity |
Used to characterize velocity distributions, thermal motion, fluctuations, and particle energies in plasmas. |
Fluid mechanics |
RMS velocity fluctuation |
Measures the magnitude of turbulent fluctuations about the mean flow. If \(u(t)=\bar{u}+u'(t)\), then \(u'_\mathrm{RMS}=\sqrt{\left\langle u'^2\right\rangle}\). |
Turbulence |
RMS turbulence intensity |
Turbulence strength is often expressed using RMS velocity fluctuations relative to mean velocity, for example \(I = u'_\mathrm{RMS}/\bar{u}\). |
Aerodynamics |
RMS pressure fluctuation |
Quantifies unsteady pressure caused by turbulence, separated flow, vortex shedding, or aerodynamic loading. |
Meteorology |
RMS wind-speed fluctuation |
Characterizes turbulent or gusting components of wind about the mean wind velocity. |
Atmospheric science |
RMS temperature fluctuation |
Used to quantify fluctuating temperature components in atmospheric turbulence and boundary-layer studies. |
Oceanography |
RMS surface displacement |
Characterizes irregular ocean-wave motion where instantaneous surface elevation varies above and below the mean level. |
Oceanography |
RMS wave velocity |
Describes the effective magnitude of oscillatory water-particle motion associated with waves and currents. |
Seismology |
RMS ground acceleration |
Summarizes the magnitude of time-varying ground acceleration produced by earthquakes, machinery, or ambient seismic noise. |
Seismology |
RMS ground velocity |
Used to characterize earthquake and ambient ground motion while avoiding cancellation between motion in opposite directions. |
Geophysics |
RMS field anomaly |
Used to describe the typical magnitude of variations in measured gravitational, magnetic, seismic, or other geophysical fields relative to a model or mean. |
Optics |
RMS wavefront error |
Measures deviations of an optical wavefront from its ideal shape. RMS wavefront error is a standard measure of optical-system quality. |
Optical engineering |
RMS spot radius |
Characterizes the spread of rays or light intensity around an image point and is used as a measure of imaging performance. |
Laser engineering |
RMS intensity fluctuation |
Used to quantify fluctuations in laser output power or optical intensity, including amplitude noise and source stability. |
Surface metrology |
RMS surface roughness |
The RMS height deviation of a surface from its mean plane, commonly written \(R_q=\sqrt{\frac{1}{L}\int_0^L z^2(x)\,dx}\). It weights large surface deviations more strongly than arithmetic-average roughness. |
Manufacturing |
RMS dimensional error |
Provides an aggregate measure of deviations between manufactured dimensions or surface coordinates and their nominal values. |
Statistics |
Standard deviation |
Standard deviation is the RMS deviation from the mean: \(\sigma=\sqrt{\left\langle(x-\mu)^2\right\rangle}\). For a zero-mean quantity, standard deviation and RMS value are identical. |
Statistics |
Root-mean-square deviation |
Measures the typical magnitude of deviations between observed values and a reference or expected value. |
Regression |
Root-mean-square error (RMSE) |
Common model-quality metric, \(\mathrm{RMSE}=\sqrt{\frac{1}{N}\sum_{i=1}^{N}(y_i-\hat{y}_i)^2}\), which weights large prediction errors more strongly than small ones. |
Machine learning |
RMSE |
Used as a loss or evaluation metric for regression models when prediction error is naturally measured in the same units as the predicted quantity. |
Numerical analysis |
RMS numerical error |
Summarizes errors between a numerical approximation and an exact, reference, or higher-accuracy solution over many points. |
Computational science |
RMS residual |
Measures the overall magnitude of residual errors remaining in a numerical solution, iterative solver, or discretized differential equation. |
Computational fluid dynamics |
RMS residual |
Used as a convergence measure for quantities such as continuity, momentum, and energy equations during iterative CFD calculations. |
Finite-element analysis |
RMS response |
Used for structures exposed to random or broadband excitation, including random-vibration and power-spectral-density analyses. |
Image processing |
RMS pixel error |
Measures the difference between two images by taking the RMS of corresponding pixel-value differences. |
Imaging |
RMS image noise |
Characterizes random variations of pixel intensity about the expected signal level. |
Computer graphics |
RMS rendering error |
Can quantify differences between a computed image and a high-quality reference image when evaluating rendering algorithms. |
Communications |
RMS error-vector magnitude |
Characterizes modulation quality by measuring the RMS distance between received constellation points and their ideal locations. |
Digital communications |
RMS phase error |
Measures the typical phase deviation of a received or generated carrier or modulated signal from its ideal value. |
Oscillators and timing |
RMS jitter |
Timing jitter is commonly described by the RMS variation of signal-edge timing relative to an ideal or recovered clock. |
Frequency standards |
RMS phase fluctuation |
Used to characterize short-term phase instability and noise in oscillators, clocks, and frequency references. |
Navigation |
RMS position error |
Measures the typical distance between estimated and true positions over repeated measurements. |
GPS/GNSS |
RMS ranging error |
Describes the statistical magnitude of pseudorange or position errors caused by receiver noise, propagation effects, clocks, and geometry. |
Surveying |
RMS coordinate error |
Used to summarize errors in measured or adjusted coordinates relative to reference positions. |
Geodesy |
RMS model residual |
Describes the typical discrepancy between observed positions, elevations, gravity measurements, or other geodetic quantities and a fitted model. |
Astronomy |
RMS photometric variation |
Quantifies fluctuations in measured stellar brightness and is used in variability studies, instrument characterization, and exoplanet observations. |
Astronomy |
RMS astrometric error |
Describes the typical positional error of measured celestial objects relative to reference coordinates. |
Radio astronomy |
RMS noise |
The RMS fluctuation of receiver or sky-noise measurements sets the noise floor and determines the detectability of weak astronomical signals. |
Spectroscopy |
RMS spectral noise |
Measures fluctuations in spectral intensity about a baseline or fitted spectrum and is often used in estimating signal-to-noise ratio. |
Medical imaging |
RMS image noise |
Used to characterize fluctuations in reconstructed CT, MRI, ultrasound, or other medical images. |
Biomedical engineering |
RMS EMG amplitude |
The RMS amplitude of an electromyography signal provides a measure of muscle activation over a selected time interval. |
Biomechanics |
RMS acceleration |
Used to quantify body-segment motion, gait variability, tremor, impact exposure, or movement intensity from accelerometer data. |
Occupational health |
RMS vibration exposure |
Used in assessing worker exposure to hand-arm or whole-body mechanical vibration over specified time intervals. |
Earthquake engineering |
RMS response |
Used to summarize structural displacement, velocity, or acceleration under earthquake excitation and other random dynamic loads. |
Civil engineering |
RMS pavement roughness or response |
Can characterize variations in road profiles or vehicle responses when evaluating pavement quality and ride comfort. |
Hydrology |
RMS model error |
Used to evaluate differences between modeled and measured quantities such as streamflow, water level, or precipitation. |
Climate science |
RMS climate-model error |
Summarizes spatial or temporal differences between model predictions and observations for quantities such as temperature or precipitation. |
Remote sensing |
RMS geolocation error |
Measures typical positional discrepancy between remotely sensed data and known reference locations. |
Photogrammetry |
RMS reprojection error |
Measures the discrepancy between observed image points and points projected from a fitted camera or geometric model. |
Computer vision |
RMS reprojection error |
Common measure of camera-calibration quality based on differences between measured and predicted image coordinates. |
Metrology |
RMS measurement error |
Describes the effective magnitude of repeated measurement deviations from a reference value or fitted model. |
Frequency-domain analysis |
RMS spectral amplitude |
RMS values can be derived from spectral components or power spectral density, allowing total signal or noise level to be obtained by summing squared contributions. |
Random-process theory |
RMS value of a stochastic process |
For a random process \(X(t)\), the RMS magnitude is \(X_\mathrm{RMS}=\sqrt{E[X^2]}\). It provides a natural measure of the strength of random quantities that may have zero mean. |
Probability theory |
RMS random variable |
The quantity \(\sqrt{E[X^2]}\) is the RMS magnitude of a random variable and combines contributions from both its mean and its variance: \(X_\mathrm{RMS}^2=\mu^2+\sigma^2\). |
Error analysis |
RMS error |
General measure for signed errors where positive and negative errors should not cancel. Squaring makes all contributions positive and places greater weight on large errors. |